EXPLORE THE ECOSYSTEM
Robotics
LeRobot, Reachy Mini, and the world of open robotics.
18 articlesNewest announcements first
Mundo reconstructs a place as an editable 3D proxy, advances it with simulation code, and uses a video model to render the result. The separation makes its controls easier to inspect while exposing clear limits around geometry, speed, and long-term consistency.
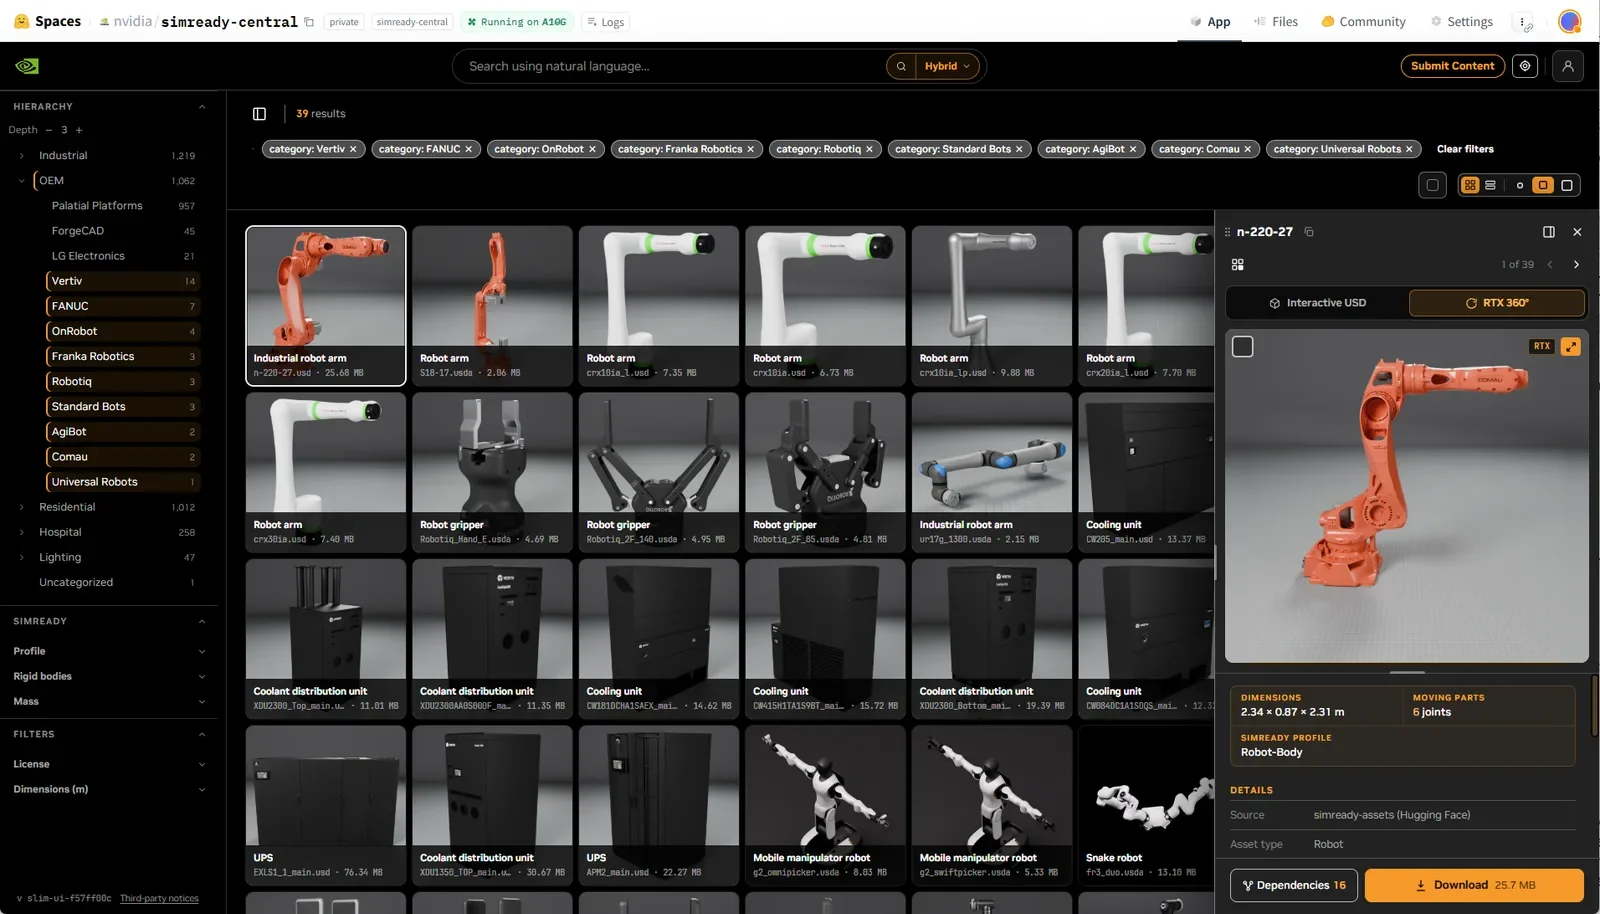
SimReady Central packages OpenUSD models with simulation metadata. The useful shift is not simply a larger asset catalog, but a more disciplined way to select, validate, version, and reuse components across robotics and digital-twin experiments.
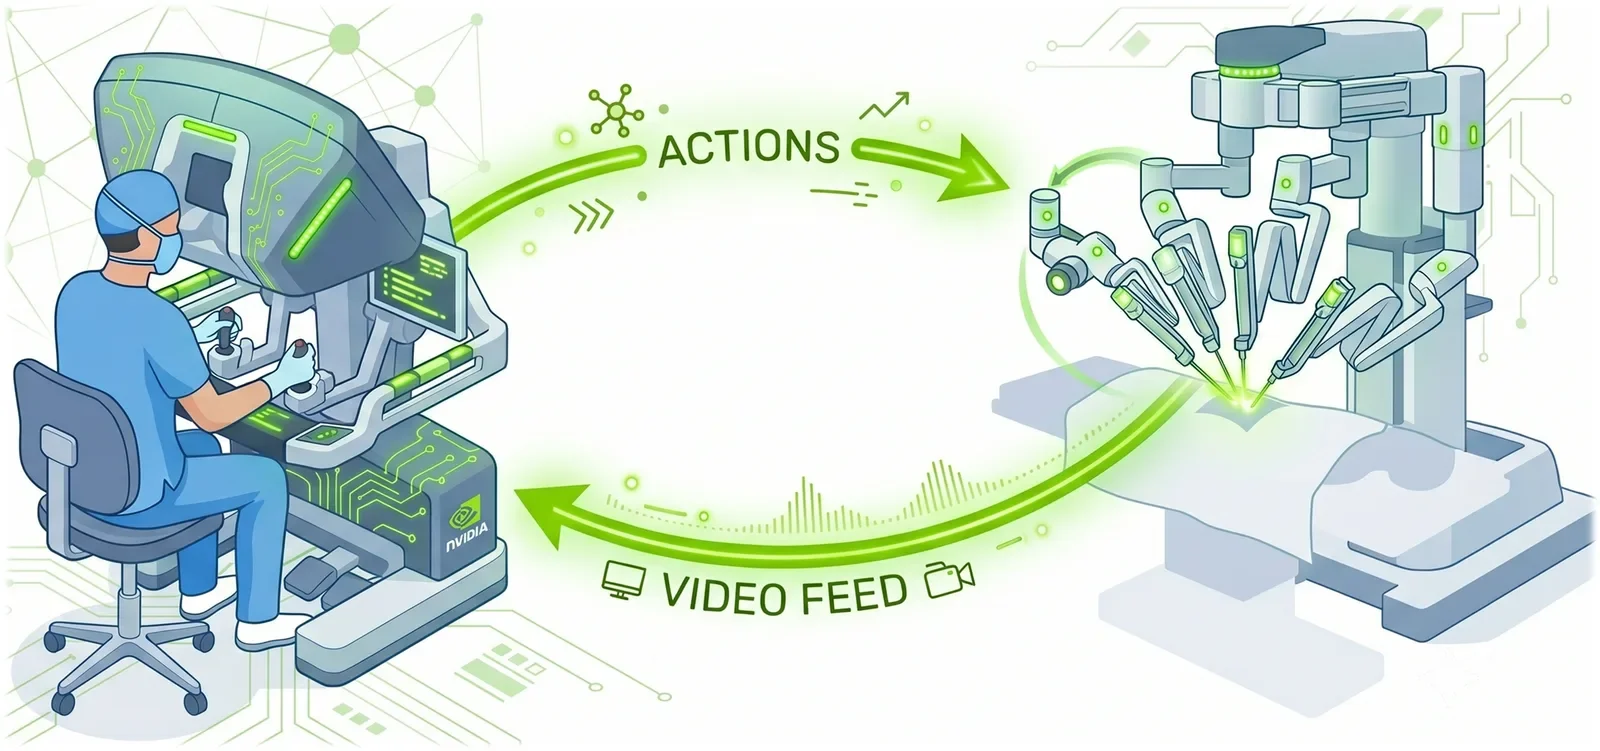
NVIDIA's Cosmos3-H-Dreams brings action-conditioned video generation into clinical surgical scenes, making validation of control fidelity, temporal stability, and safety boundaries the central engineering challenge.
FiftyOne's native LeRobot v3 reader turns recorded episodes into queryable dataset entries, making it easier to inspect coverage, find redundancy, and define reproducible training subsets.
ProjectSim argues that robotics evaluation should connect observed failures to targeted training data. The practical challenge is designing benchmarks that separate perception, control, recovery, and real-world robustness while keeping simulation honest.
A new Unitree G1 workflow in LeRobot uses learned motion tokens and a fast whole-body controller, illustrating why humanoid policies benefit from a layered control stack.
LeRobot's LanceDB integration turns one robotics dataset into a remote training source, search index, and curation workspace. The important shift is not just faster loading, but a simpler path from inspecting failures to defining the next training set.
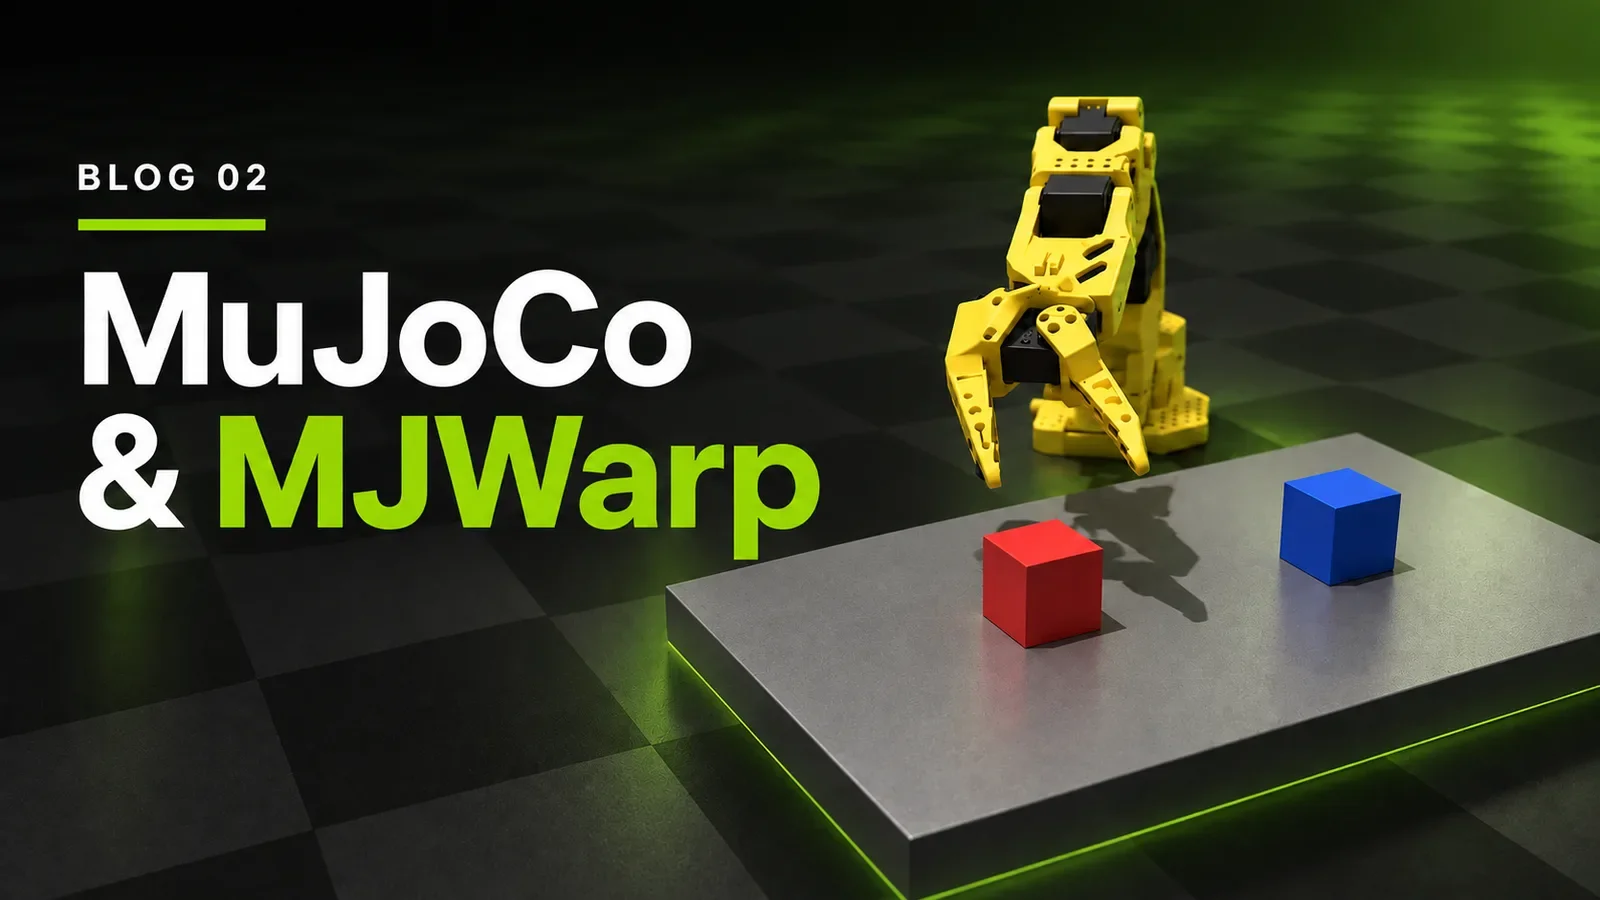
NVIDIA’s Warp and MuJoCo Warp can batch compatible robot simulations on a GPU. The important engineering work is preserving task behavior, sizing resources, and measuring throughput without confusing queue time for completed physics.
Grabette makes handheld manipulation capture part of the open robotics workflow. The next challenge is collecting demonstrations that remain useful beyond the room where they were recorded.

The release added tools for closing the loop between a learned policy and what happens on a robot.
 Article·6 min